Product Core Brief
- Model: DSQC346U
- Order Code: 3HAB8101-13
- Brand: ABB
- Series: ABB IRC5 Robot Controllers
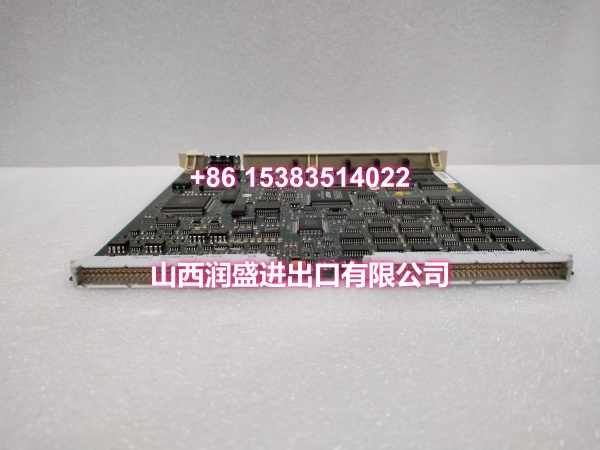
- Core Function: Drive control unit that manages and controls the robot’s drive system — processes motion control commands from the controller and coordinates with drive modules to precisely control robot axis motor operation, ensuring the robot executes programmed trajectories with high precision and stability.
- Product Type: Drive Control Unit
- Key Specs: High-speed digital communication with controller | Real-time motion control processing | Comprehensive drive system protection | Modular plug-in design for IRC5 control cabinets
- Condition: New Original / New Surplus
Key Technical Specifications
- Product Type: Drive Control Unit for ABB IRC5 Robot Controllers
- Brand: ABB
- Model Number:
- Order Code: 3HAB8101-13
- Series: ABB IRC5 Robot Controllers
- Core Function: Manages and controls the robot’s drive system — processes motion control commands from the controller and coordinates with drive modules to precisely control robot axis motor operation, ensuring the robot executes programmed trajectories with high precision and stability
- Communication Interface: High-speed digital communication with the robot controller — ensures motion commands are transmitted in real time for fast response and synchronized multi-axis control
- Control Processing: Handles real-time motion control computations including position, velocity, and torque control loops — works in conjunction with the axis computer (e.g., DSQC668) to process encoder feedback and execute closed-loop control
- Drive System Coordination: Interfaces with drive modules (e.g., DSQC346G, DSQC406) to coordinate power delivery to servo motors — ensures each axis receives the correct drive signals for smooth, accurate motion
- Protection Functions: Integrated protection mechanisms for the drive system — monitors for overcurrent, overvoltage, undervoltage, overheating, and motor overload conditions, triggering protective shutdowns when abnormalities are detected
- Mounting Method: Modular plug-in design for IRC5 control cabinet drive unit rack — enables straightforward like-for-like replacement during maintenance
- Operating Temperature: Designed for industrial control cabinet environments (0°C to +70°C)
- Environmental Rating: IP20 (control cabinet environment)
- Product Status: Discontinued (spare parts supply) — compatible with ABB IRC5 controller ecosystems
- Typical Applications: Drive control for ABB IRC5-controlled industrial robots — managing drive system operation in handling, welding, assembly, palletizing, and other automation applications; serving as a critical spare part for lifecycle support of mature IRC5 robot installations where drive control unit replacement is required
Product Introduction
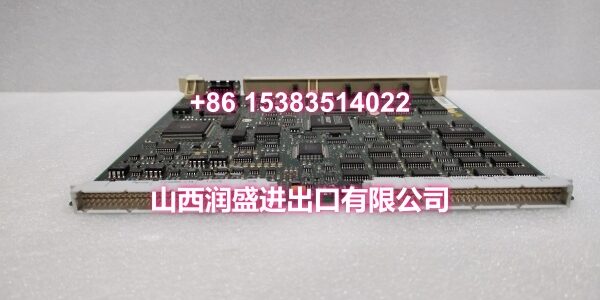
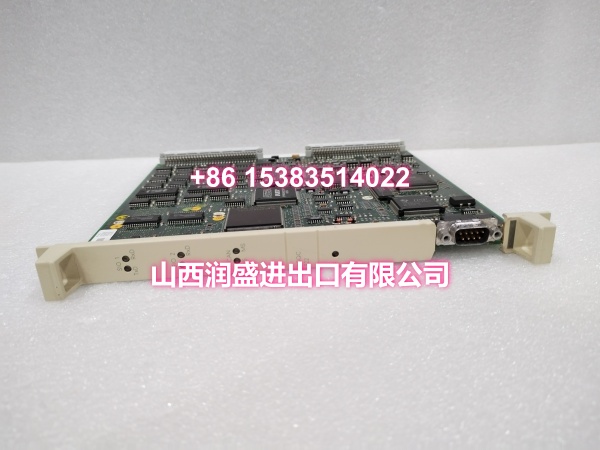
The ABB DSQC346U (order code 3HAB8101-13) is a drive control unit designed for ABB’s IRC5 robot controllers, engineered to serve as the critical link between the controller’s motion planning system and the robot’s drive modules. In an automated robot cell, the DSQC346U handles the essential task of processing and managing drive system operations — receiving motion commands from the controller’s main computer and axis computer, coordinating with individual drive modules, and ensuring that each servo motor receives the correct control signals to execute precise, synchronized motion across all robot axes.
What distinguishes the DSQC346U in IRC5 installations is its role as the drive system’s central coordinator. While drive modules like the DSQC346G handle the power conversion that physically drives the motors, the DSQC346U manages the higher-level control logic — processing real-time feedback from encoders, executing motion control algorithms, and ensuring that all axes operate in harmony. This separation of control and power functions is a hallmark of ABB’s modular IRC5 architecture, allowing for easier troubleshooting, maintenance, and component replacement.
The DSQC346U’s high-speed digital communication interface ensures that motion commands are transmitted between the controller and drive system with minimal latency. In applications such as arc welding, precision assembly, or high-speed pick-and-place, even microsecond-level delays can manifest as path deviation or reduced repeatability. The DSQC346U’s real-time processing capability ensures that the robot maintains the tight axis synchronization that ABB robots are known for, even during complex multi-axis maneuvers.
For system integrators and maintenance engineers supporting mature IRC5 robot installations, the DSQC346U is a critical spare part. As a discontinued product, availability of genuine units is essential for lifecycle support — a drive control unit failure can render the entire robot inoperable, as the controller can no longer coordinate with the drive modules. The DSQC346U’s modular plug-in form factor means replacement is a straightforward like-for-like swap: the failed unit is removed from the drive unit rack, the new unit is inserted into the same position, and after verifying connections and configuration, the system can be restarted, minimizing downtime during maintenance windows.
QA & Testing SOP
Every unit undergoes a standardized verification process before shipment:
- Visual & Anti-Counterfeit Check: Inspect the module housing for proper ABB branding and part number marking (DSQC346U, 3HAB8101-13). Check for physical damage including cracked housing, damaged connector pins, burnt components, or signs of moisture ingress (corrosion, white residue on contacts).
- Connector Pin Inspection: Examine all connector pins (controller communication, drive module interface, power) for straightness, corrosion, or bending. Damaged pins can cause intermittent connections or communication errors.
- Communication Interface Test: Establish communication with an IRC5 controller and verify that the DSQC346U is recognized correctly with no communication errors. Verify that command transmission and response times are within specification.
- Drive System Coordination Test: Connect the DSQC346U to representative drive modules and verify that it correctly coordinates drive operation — sending control signals, receiving feedback, and managing multi-axis synchronization.
- Protection Function Tests:
- Overcurrent: Simulate overcurrent conditions and verify that the DSQC346U triggers appropriate protective responses.
- Overvoltage/Undervoltage: Apply abnormal supply voltages and verify that voltage protection functions activate correctly.
- Overheating: Raise module temperature and verify that thermal protection activates within specification.
- Motor overload: Simulate motor overload conditions and verify that the protection triggers appropriately.
- Long-Duration Stability Test: Run the DSQC346U under continuous operation for an extended period to verify stable performance with no communication dropouts, control errors, or protection false trips.
- Anti-Static & Mechanical Protection: After passing all tests, the module is placed in anti-static shielding with protective caps on connectors. It is then packed in rigid cardboard with foam cushioning to prevent mechanical shock and ESD damage during transit.
Installation Pitfalls & Guide
Real-World Risks When Replacing This Module:
❗ Controller Compatibility: The DSQC346U is designed for ABB IRC5 robot controllers. It is not compatible with older S-Series (S3/S4/S4C) controllers, which use different drive control architectures (e.g., DSQC236, DSQC345 series). It is also not directly interchangeable with OmniCore controller components, as OmniCore uses a completely different drive architecture. Always verify your controller model before ordering.
❗ Drive Unit Configuration: The IRC5 controller stores drive unit configuration parameters (motor types, gear ratios, calibration data, axis assignments) in the controller memory. After installing a replacement DSQC346U, the controller should recognize the module automatically if the configuration is intact. However, if the controller memory has been lost or if the replacement unit has different firmware, you may need to reconfigure the drive unit parameters from the teach pendant and perform motor calibration (revolution counter update) before the robot can operate correctly.
❗ Incorrect Slot Placement: The DSQC346U must be installed in the correct drive unit slot position specified in the IRC5 controller’s configuration. Installing it in the wrong slot can prevent the controller from recognizing the module, resulting in drive communication errors or axis faults. Always verify the slot assignment matches the system documentation and the labeling on the drive unit rack before insertion.
❗ Connection Verification: After replacing the module, verify that all communication and power connections are secure and correctly terminated. Loose connections can cause intermittent communication errors or drive faults that are difficult to diagnose. Verify that cable connectors are fully seated and that locking mechanisms are engaged.
❗ Grounding Requirements: Ensure that the drive control unit and associated drive modules are properly grounded. Improper grounding can cause electrical noise issues, EMI interference, and communication errors.
❗ Power-Down Requirement: Always power down the IRC5 controller and verify that the DC bus capacitors have fully discharged before inserting or removing drive control units. The DC bus can retain dangerous voltage levels for several minutes after power is removed. Use a multimeter to verify that the DC bus voltage is below safe levels before handling the module.
4-Step Replacement Guide:
- Pre-Install: Identify the failed DSQC346U slot position in the IRC5 drive unit rack. Document the existing drive unit configuration from the teach pendant or backup files. If possible, back up the current controller configuration before proceeding. Power down the IRC5 controller, disconnect the main power supply, and verify that the DC bus capacitors have fully discharged (DC bus voltage < 50V).
- Removal: Disconnect all communication and power cables from the DSQC346U module. Release the module locking mechanism and carefully slide the old module out of the drive unit rack slot. Inspect the rack connector and cables for damage or debris.
- Install: Insert the new DSQC346U module into the correct drive unit rack slot, ensuring proper alignment with the backplane connector. Secure the module with the locking mechanism. Reconnect all communication and power cables, verifying correct terminal assignments and that connectors are fully seated.
- Power-On Test: Reconnect the main power supply and power up the IRC5 controller. Verify that the controller recognizes the DSQC346U module with no drive communication errors. Check the module status LEDs for normal operation. If required, perform motor calibration (revolution counter update) from the teach pendant. Run a test program at low speed to verify that all axes move correctly with no abnormal noise, vibration, or fault conditions. Gradually increase speed to full operational range and verify stable performance.
Technical FAQ
What is the difference between the DSQC346U and DSQC346G? The DSQC346U is a drive control unit that manages and coordinates the drive system — it handles the control logic, communication, and protection monitoring. The DSQC346G is a servo drive module that handles the power conversion — it converts digital control signals into electrical power that drives the servo motors. In the IRC5 architecture, the DSQC346U acts as the “brain” of the drive system, while the DSQC346G acts as the “muscle.” They work together but serve different functions.
Can the DSQC346U be used in S4/S4C or OmniCore controllers? No. The DSQC346U is designed exclusively for ABB IRC5 robot controllers. S4/S4C controllers use different drive control architectures (e.g., DSQC345 series), and OmniCore controllers use a completely different drive architecture. Always verify your controller model before ordering drive control units.
What are common failure modes for this module? Common failure modes include: communication interface failure from electrical noise or connector issues; control processing errors from component degradation; protection circuit malfunction; and connector pin damage from repeated insertion/removal. In most cases, a failing DSQC346U will trigger drive communication errors or axis faults in the controller diagnostics, which can be read from the teach pendant to identify the specific fault type.
Is the DSQC346U still in production? The DSQC346U is a discontinued product, with supply now limited to spare parts inventory (New Original / New Surplus). ABB announced that the IRC5 controller platform will be gradually phased out starting June 2026, with OmniCore as its replacement. However, ABB has committed to continuing spare parts and service support for IRC5 installations throughout the remaining service life of deployed robots. For plants maintaining IRC5 robot installations, having verified genuine DSQC346U units on hand is critical for lifecycle support.
What warranty do you offer on New Surplus parts? We provide a full 12-month warranty on all New Original / New Surplus units. This is fundamentally different from refurbished or pulled modules, which often carry 30–90 day warranties and come with unknown operational history, potential connector wear, and degraded component performance. For a drive control unit that is critical to robot motion coordination, the reliability difference between new surplus and refurbished directly impacts production uptime and the risk of unexpected drive faults.